All skills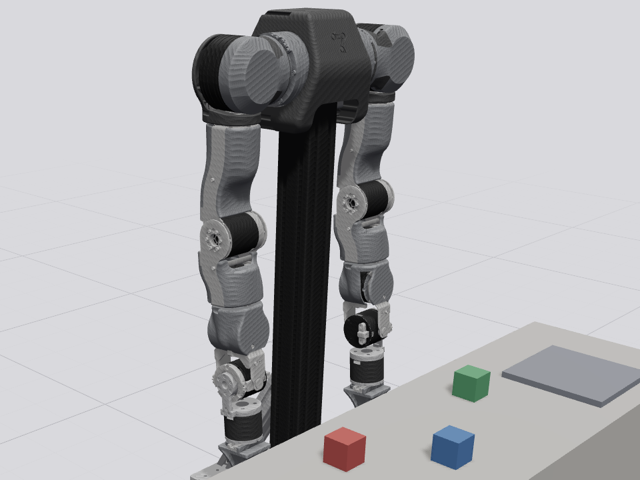
Real physics, in this tab. Nothing to install and no account. The first run downloads the robot runtime, about 14 MB.
Bimanual arm · OpenArm v1
transfer red right to left tray
Pick up the red block with the right arm, hand it to the left arm, and place it in the left tray.
taught their robot this by typing a sentence. It ran successfully, so it was published. What you see is the same program running against the same physics.
transfer_red_right_to_left_tray.py
META = {"name": "transfer_red_right_to_left_tray", "description": "Pick up the red block with the right arm, hand it to the left arm, and place it in the left tray.", "params": {}}

def run(ctx, **params):
    scene = ctx.describe_scene()
    red = scene["objects"]["red_block"]["position"]
    tray = scene["fixtures"]["tray_left"]["position"]
    open_r = ctx.gripper_range("right")[0]
    closed_r = ctx.gripper_range("right")[1]
    open_l = ctx.gripper_range("left")[0]
    closed_l = ctx.gripper_range("left")[1]
    high = red[2] + 0.12
    ctx.gripper("right", open_r)
    ctx.move_to_point("right", [red[0], red[1], high])
    ctx.move_to_point("right", red)
    ctx.gripper("right", closed_r)
    ctx.move_to_point("right", [red[0], red[1], high])
    handoff = [tray[0], tray[1], tray[2] + 0.12]
    ctx.gripper("left", open_l)
    ctx.move_to_point("left", handoff)
    ctx.gripper("left", closed_l)
    ctx.gripper("right", open_r)
    ctx.move_to_point("left", [tray[0], tray[1], tray[2] + 0.06])
    ctx.gripper("left", open_l)
    ctx.move_to_point("left", handoff)