Skills that ran.
Every program here was taught by typing, written by the agent, and seen to run to completion on the robot it is filed under. Every successful skill, on any robot, by anyone, lands here on its own. Nothing is listed on a promise. Copy one, or teach your own.
19
published skills
6
robots
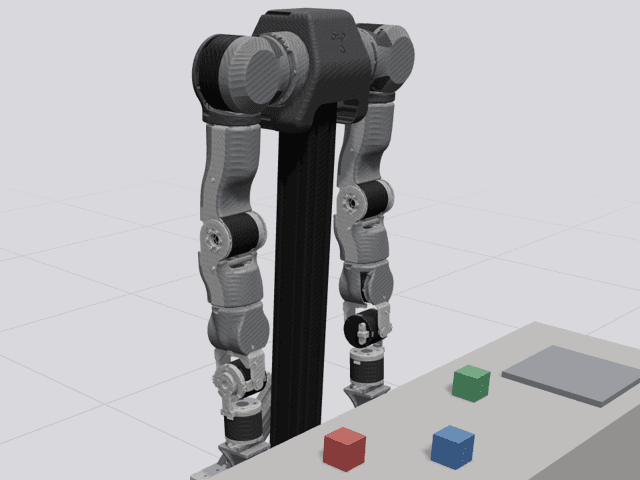
OpenArm v1 (bimanual)
4 skillsTwo arms, seven joints each
Bimanual arm · 7 joints × 2 · 0.65 m reach · runs in your browser
A bimanual research arm with parallel-jaw grippers. Left and right trays and a small pocket on a shared bench, three blocks. The body BotCortex was built on.
Teach this robot in your browser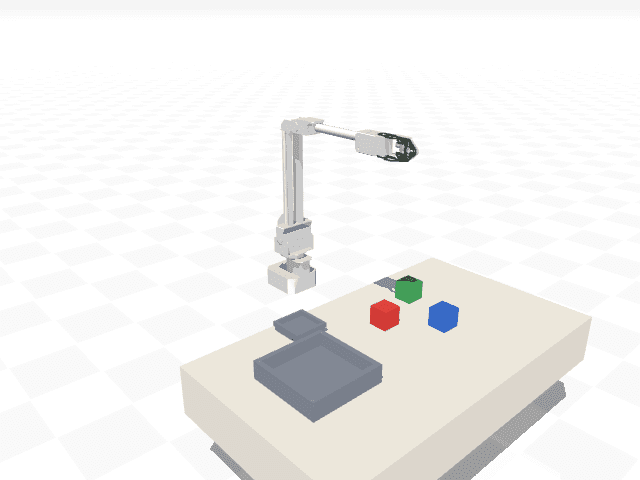
Waveshare RoArm-M2 (S/Pro)
4 skillsOne arm, three joints, a clamp
Robot arm · 3 joints · 0.5 m reach · runs in your browser
Waveshare's desktop arm: a single hinged clamp and about half a metre of reach, one tray and a pocket it cannot yaw a block into. Cheap, and honest about what it cannot orient.
Teach this robot in your browser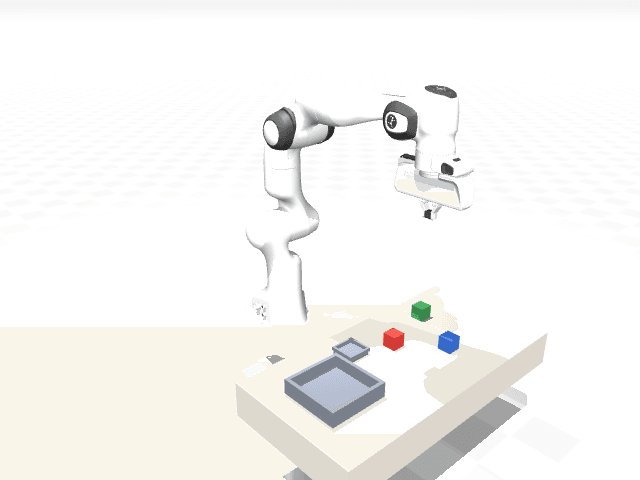
Franka Emika Panda (MuJoCo Menagerie)
3 skillsOne arm, seven joints, a two-finger hand
Robot arm · 7 joints · 0.855 m reach · runs in your browser
The Franka Emika Panda from MuJoCo Menagerie: the lab-standard collaborative arm, 0.85 m of reach, a tendon-driven parallel gripper. Simulates in the browser.
Model and meshes: MuJoCo Menagerie · Franka Emika Panda, Apache-2.0.
Teach this robot in your browser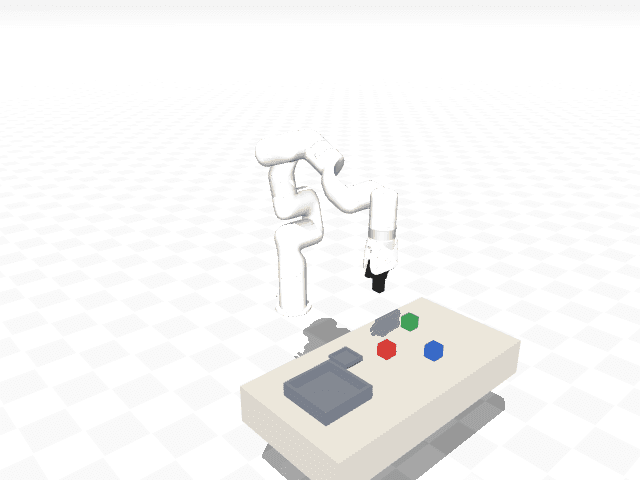
UFACTORY xArm7 (MuJoCo Menagerie)
0 skillsOne arm, seven joints, a parallel gripper
Robot arm · 7 joints · 0.7 m reach · runs in your browser
UFACTORY's xArm7 from MuJoCo Menagerie, standing on its pedestal: 0.7 m of reach and a two-finger gripper. Simulates in the browser.
Model and meshes: MuJoCo Menagerie · UFACTORY xArm7, BSD-3-Clause.
Teach this robot in your browserNothing proven on this robot yet. The first skill that runs to completion on it lands here on its own.
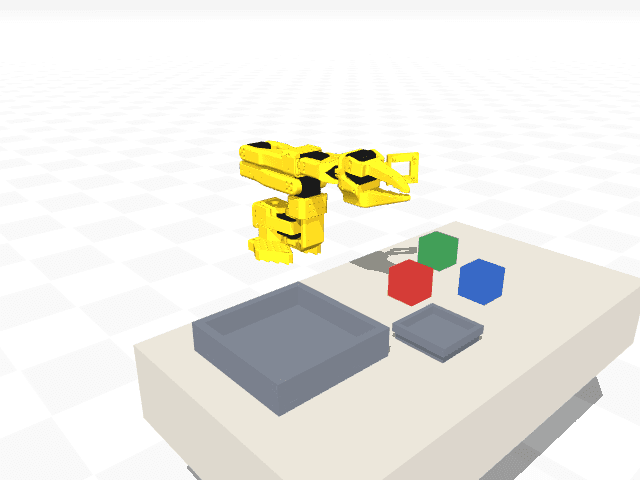
SO-101 (LeRobot, MuJoCo Menagerie)
7 skillsOne arm, five joints, a printed jaw
Robot arm · 5 joints · 0.3 m reach · runs in your browser
The LeRobot community's SO-101 from MuJoCo Menagerie: five hobby servos, 30 cm of reach, a 3D-printed clamp. The arm most people teaching a robot for the first time own. Simulates in the browser.
Model and meshes: MuJoCo Menagerie · SO-101, Apache-2.0.
Teach this robot in your browser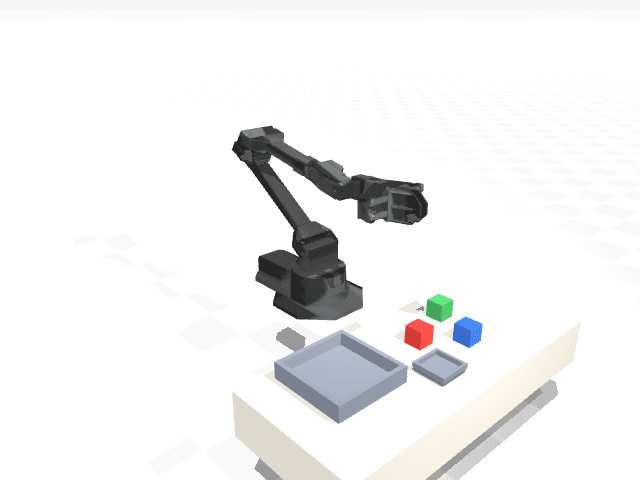
Trossen ViperX 300s (ALOHA, MuJoCo Menagerie)
1 skillOne arm, six joints, a parallel gripper
Robot arm · 6 joints · 0.55 m reach · runs in your browser
Trossen's ViperX 300s from MuJoCo Menagerie, the ALOHA arm: six joints, 55 cm of reach, a two-finger gripper whose wrist sags a little at full stretch. Simulates in the browser.
Model and meshes: MuJoCo Menagerie · Trossen ViperX 300s, BSD-3-Clause.
Teach this robot in your browser