All skills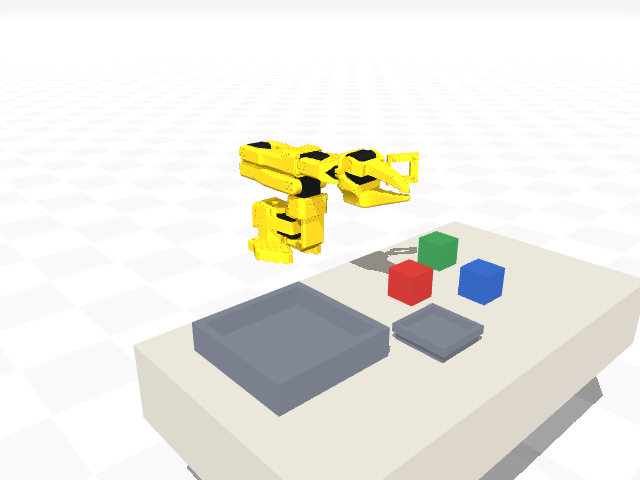
Real physics, in this tab. Nothing to install and no account. The first run downloads the robot runtime, about 14 MB.
Robot arm · SO-101
place held object in fixture
Place the currently held named object inside a named fixture
taught their robot this by typing a sentence. It ran successfully, so it was published. What you see is the same program running against the same physics.
Model and meshes: MuJoCo Menagerie · SO-101, Apache-2.0.
place_held_object_in_fixture.py
META = {"name": "place_held_object_in_fixture", "description": "Place the currently held named object inside a named fixture", "params": {"object": "red_block", "fixture": "slot", "arm": "arm"}}

def run(ctx, **params):
    arm = params.get("arm", "arm")
    obj = params.get("object", "red_block")
    fixture = params.get("fixture", "slot")
    ctx.describe_scene()
    ctx.place_in(arm, fixture, obj)